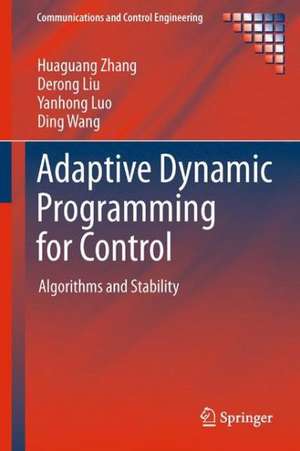
Adaptive Dynamic Programming for Control: Communications and Control Engineering
Autor Huaguang Zhang, Derong Liu, Yanhong Luo, Ding Wangen Limba Engleză Hardback – 14 dec 2012
• infinite-horizon control for which the difficulty of solving partial differential Hamilton–Jacobi–Bellman equations directly is overcome, and proof provided that the iterative value function updating sequence converges to the infimum of all the value functions obtained by admissible control law sequences;
• finite-horizon control, implemented in discrete-time nonlinear systems showing the reader how to obtain suboptimal control solutions within a fixed number of control steps and with results more easily applied in real systems than those usually gained from infinite-horizon control;
• nonlinear games for which a pair of mixed optimal policies are derived for solving games both when the saddle point does not exist, and, when it does, avoiding the existence conditions of the saddle point.
Non-zero-sum games are studied in the context of a single network scheme in which policies are obtained guaranteeing system stability and minimizing the individual performance function yielding a Nash equilibrium.
In order to make the coverage suitable for the student as well as for the expert reader, Adaptive Dynamic Programming in Discrete Time:
• establishes the fundamental theory involved clearly with each chapter devoted to aclearly identifiable control paradigm;
• demonstrates convergence proofs of the ADP algorithms to deepen understanding of the derivation of stability and convergence with the iterative computational methods used; and
• shows how ADP methods can be put to use both in simulation and in real applications.
This text will be of considerable interest to researchers interested in optimal control and its applications in operations research, applied mathematics computational intelligence and engineering. Graduate students working in control and operations research will also find the ideas presented here to be a source of powerful methods for furthering their study.
Din seria Communications and Control Engineering
- 20%
 Preț: 912.34 lei
- 18%
 Preț: 992.26 lei
- 18%
 Preț: 1169.33 lei
- 18%
 Preț: 1154.10 lei
- 15%
 Preț: 680.73 lei
- 18%
 Preț: 929.37 lei
- 15%
 Preț: 667.91 lei
- 18%
 Preț: 987.63 lei
- 18%
 Preț: 1451.74 lei
- 18%
 Preț: 952.84 lei
- 18%
 Preț: 983.93 lei
- 18%
 Preț: 916.16 lei
- 23%
 Preț: 1004.58 lei
- 18%
 Preț: 988.90 lei
- 15%
 Preț: 675.30 lei
- 18%
 Preț: 991.00 lei
- 18%
 Preț: 1087.77 lei
- 18%
 Preț: 925.04 lei
- 18%
 Preț: 1144.83 lei
- 18%
 Preț: 1193.65 lei
- 24%
 Preț: 1061.48 lei
- 18%
 Preț: 982.79 lei
- 18%
 Preț: 981.00 lei
- 18%
 Preț: 1119.01 lei
- 18%
 Preț: 1431.25 lei
- 18%
 Preț: 990.53 lei
- 15%
 Preț: 668.95 lei
- 18%
 Preț: 980.46 lei
- 15%
 Preț: 598.26 lei
- 15%
 Preț: 668.10 lei
- 20%
 Preț: 1500.71 lei
- 15%
 Preț: 666.14 lei
- 18%
 Preț: 1279.56 lei
- 15%
 Preț: 674.64 lei
- 18%
 Preț: 821.53 lei
- 18%
 Preț: 990.77 lei
- 18%
 Preț: 1079.91 lei
- 18%
 Preț: 988.26 lei
- 18%
 Preț: 1270.25 lei
- 15%
 Preț: 670.23 lei
Preț: 992.48 lei
Preț vechi: 1210.34 lei
-18%
Puncte Express: 1489
Carte tipărită la comandă
Livrare economică 01-15 decembrie
Livrare prin curier în România Termenul estimat este afișat lângă disponibilitate.
Transport gratuit pentru acest produs Plată online sau ramburs, în funcție de opțiunile comenzii.
Retur gratuit în 14 zile Comandă securizată și suport în română.
Specificații
ISBN-13: 9781447147565
ISBN-10: 1447147561
Pagini: 440
Ilustrații: XVI, 424 p.
Dimensiuni: 160 x 241 x 29 mm
Greutate: 0.77 kg
Ediția:2013
Editura: Springer
Colecția Communications and Control Engineering
Seria Communications and Control Engineering
Locul publicării:London, United Kingdom
ISBN-10: 1447147561
Pagini: 440
Ilustrații: XVI, 424 p.
Dimensiuni: 160 x 241 x 29 mm
Greutate: 0.77 kg
Ediția:2013
Editura: Springer
Colecția Communications and Control Engineering
Seria Communications and Control Engineering
Locul publicării:London, United Kingdom
V-ar putea interesa
-
 -39%Preț: 359.16 lei590.66 lei
-
 -38%Preț: 160.69 lei260.20 lei
-
 -37%Preț: 162.44 lei259.50 lei
-
 Fundamentals of Object TrackingSubhash Challa-11%Preț: 730.64 lei820.93 lei
-
 Arduino Projects For DummiesBrock CraftPreț: 162.53 lei
-
 Arduino AdventuresJames Floyd Kelly-20%Preț: 225.26 lei281.57 lei
-
 Engineering Systems Integration: Theory, Metrics, and MethodsGary O. Langford-20%Preț: 1309.34 lei1636.68 lei
-
 Make: Arduino Bots and GadgetsTero KarvinenPreț: 210.49 lei
-
 Geometric Methods and ApplicationsJean Gallier-15%Preț: 552.23 lei649.67 lei
-
 Model Predictive ControlEduardo F. Camacho-15%Preț: 512.40 lei602.82 lei
-
 Mechatronic SystemsRolf Isermann-15%Preț: 605.64 lei712.51 lei
-
 Logistik-Wörterbuch. Dictionary of LogisticsVanessa Scott-Sabic-18%Preț: 838.28 lei1022.30 lei
-
 Automotive Mechatronics: Operational and Practical IssuesB. T. Fijalkowski-18%Preț: 1194.66 lei1456.91 lei
Public țintă
ResearchCuprins
Optimal Stabilization Control for Discrete-time Systems.- Optimal Tracking Control for Discrete-time Systems.- Optimal Stabilization Control for Nonlinear Systems with Time Delays.- Optimal Tracking Control for Nonlinear Systems with Time-delays.- Optimal Feedback Control for Continuous-time Systems via ADP.- Several Special Optimal Feedback Control Designs Based on ADP.- Zero-sum Games for Discrete-time Systems Based on Model-free ADP.- Nonlinear Games for a Class of Continuous-time Systems Based on ADP.- Other Applications of ADP.
Recenzii
From the book reviews:
“This book provides a self-contained treatment of adaptive dynamic programming with applications in feedback control and game theory. … This book … will appeal to graduate students, practitioners, and researchers seeking an up-to-date and consolidated treatment of the field.” (IEEE Control Systems Magazine, October, 2013)
“This book provides a self-contained treatment of adaptive dynamic programming with applications in feedback control and game theory. … This book … will appeal to graduate students, practitioners, and researchers seeking an up-to-date and consolidated treatment of the field.” (IEEE Control Systems Magazine, October, 2013)
Textul de pe ultima copertă
There are many methods of stable controller design for nonlinear systems. In seeking to go beyond the minimum requirement of stability, Adaptive Dynamic Programming for Control approaches the challenging topic of optimal control for nonlinear systems using the tools of adaptive dynamic programming (ADP). The range of systems treated is extensive; affine, switched, singularly perturbed and time-delay nonlinear systems are discussed as are the uses of neural networks and techniques of value and policy iteration. The text features three main aspects of ADP in which the methods proposed for stabilization and for tracking and games benefit from the incorporation of optimal control methods:
• infinite-horizon control for which the difficulty of solving partial differential Hamilton–Jacobi–Bellman equations directly is overcome, and proof provided that the iterative value function updating sequence converges to the infimum of all the value functions obtained by admissible control law sequences;
• finite-horizon control, implemented in discrete-time nonlinear systems showing the reader how to obtain suboptimal control solutions within a fixed number of control steps and with results more easily applied in real systems than those usually gained from infinte-horizon control;
• nonlinear games for which a pair of mixed optimal policies are derived for solving games both when the saddle point does not exist, and, when it does, avoiding the existence conditions of the saddle point.
Non-zero-sum games are studied in the context of a single network scheme in which policies are obtained guaranteeing system stability and minimizing the individual performance function yielding a Nash equilibrium.
In order to make the coverage suitable for the student as well as for the expert reader, Adaptive Dynamic Programming for Control:
• establishes the fundamental theory involved clearly with each chapter devoted to aclearly identifiable control paradigm;
• demonstrates convergence proofs of the ADP algorithms to deepen undertstanding of the derivation of stability and convergence with the iterative computational methods used; and
• shows how ADP methods can be put to use both in simulation and in real applications.
This text will be of considerable interest to researchers interested in optimal control and its applications in operations research, applied mathematics computational intelligence and engineering. Graduate students working in control and operations research will also find the ideas presented here to be a source of powerful methods for furthering their study.
The Communications and Control Engineering series reports major technological advances which have potential for great impact in the fields of communication and control. It reflects research in industrial and academic institutions around the world so that the readership can exploit new possibilities as they become available.
Caracteristici
Convergence proofs of the algorithms presented teach readers how to derive necessary stability and convergence criteria for their own systems Establishes the fundamentals of ADP theory so that student readers can extrapolate their learning into control, operations research and related fields Applications examples show how the theory can be made to work in real example systems Includes supplementary material: sn.pub/extras
Notă biografică
Juan Zhang received the B.S. degree in information and computing science from Shanxi Normal University, Linfen, China, in 2016, and the M.S. degree in basic mathematics and the Ph.D. degree in control theory and control engineering from Northeastern University, Shenyang, China, in 2018 and 2023, respectively. She is currently a Lecturer with the School of Information Science and Engineering, Northeastern University, where she is also a Post-Doctoral Fellow. Her current research interests include containment control, event-triggered control, formation control, consensus control, fault-tolerant control, DoS attacks for multi-agent systems, and their applications in boiler systems.
Huaguang Zhang (Fellow, IEEE) received the B.S. and M.S. degrees in control engineering from Northeast Dianli University, Jilin, China, in 1982 and1985, respectively, and the Ph.D. degree in thermal power engineering and automation from Southeast University, Nanjing, China, in 1991. He has authored or coauthored over 280 journals and conference papers, six monographs, and coinvented 90 patents. His current research interests include fuzzy control, stochastic system control, neural networks-based control, nonlinear control, and their applications. He was Recipient of the Outstanding Youth Science Foundation Award from the National Natural Science Foundation Committee of China in 2003 and the IEEE Transactions on Neural Networks and Learning systems Outstanding Paper Award in 2012. He was named the Cheung Kong Scholar by the Education Ministry of China in 2005. He is E-Letter Chair of the IEEE CIS Society and Former Chair of the Adaptive Dynamic Programming and Reinforcement Learning Technical Committee of the IEEE Computational Intelligence Society. He was Associate Editor of the IEEE Transactions on Fuzzy Systems from 2008 to 2013. He is Associate Editor of Automatica, the IEEE Transactions on Neural Networks and Learning Systems, the IEEE Transactions on Cybernetics, and Neurocomputing.
Dongsheng Yang (Senior Member, IEEE) received the B.S. degree in testing technology and instrumentation, the M.S. degree in power electronics and electric drives, and the Ph.D. degree in control theory and control engineering from Northeastern University, Shenyang, China, in 1999, 2004, and 2007, respectively. He is currently Professor with Northeastern University. He was supported by the Program for New Century Excellent Talents in University. He has authored or coauthored more than 70 papers published in academic journals and conference proceedings, three monographs, and coinvented 80 patents. His current research interests include distributed generation, multi-energy power systems, and artificial intelligence-based fault diagnosis and protection. He was a recipient of the Second Prize of National Science and Technology Progress.
Yanhong Luo (Member, IEEE) received the B.S. degree in automation control, the Ph.D. degree in control theory and control engineering from Northeastern University, Shenyang, China, in 2003 and 2009, respectively. From 2016 to 2017, she visited The University of Texas at Arlington as
a Visiting Scholar. She is currently a Professor with Northeastern University. She has published more than 100 SCI/EI indexed papers. Her research interests include renewable energy accommodation, distributed control and optimal operation of energy Internet, adaptive dynamic programming, and data-driven self-learning control and its industrial applications. She is a recipient of Andrew P. Sage Best Transactions Paper Award (2015) with IEEE SMC Society. In addition, she is the Former Vice-Chair of Adaptive Dynamic Programming Reinforcement Learning Technical Committee with IEEE Computational Intelligence Society.She served as the Session Chair or a TPC member for more than 20 international conferences.
Bowen Zhou (Member, IEEE) received the B.Sc. and M.Sc. degrees in electrical engineering from Wuhan University,