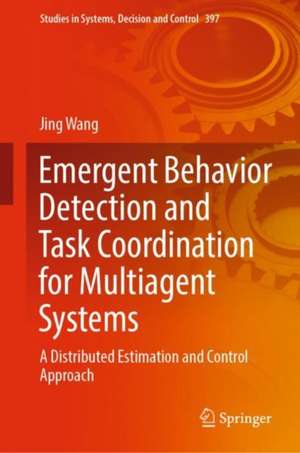
Emergent Behavior Detection and Task Coordination for Multiagent Systems: Studies in Systems, Decision and Control, cartea 397
Autor Jing Wangen Limba Engleză Hardback – 24 oct 2021
Four aspects of the technical solutions in the book are presented: First, the impact of interaction dynamics on the convergence conditions related to interaction topologies is discussed, utilizing a discontinuous cooperative control algorithm of updated design. Second, distributed least-squares and Kalman filtering algorithms for agents with limited interactions are elaborated upon. Third, a general framework of distributed nonlinear control is established, and distributed adaptive control for nonlinear systems with more general uncertainties is presented. Based on the proposed framework, a distributed nonlinear controller is designed to deal with task coordination of robotic systems with nonholonomic constraints. Finally, the problem of optimal multiagent task coordination is addressed and solutions based on approximate dynamic programming and approximate distributed gradient estimation are presented.
Emergent Behavior Detection and Task Coordination for Multiagent Systems is of interest to practicing engineers in areas such as robotics and cyber-physical systems, researchers in the field of systems, controls, and robotics, and senior undergraduate and graduate students.
Din seria Studies in Systems, Decision and Control
- 20%
 Preț: 1040.28 lei
- 18%
 Preț: 974.44 lei
- 18%
 Preț: 1072.97 lei
- 18%
 Preț: 757.54 lei
- 15%
 Preț: 667.41 lei
- 18%
 Preț: 933.89 lei
- 18%
 Preț: 1437.33 lei
- 18%
 Preț: 1049.94 lei
- 15%
 Preț: 673.58 lei
- 18%
 Preț: 1071.47 lei
- 18%
 Preț: 1046.12 lei
- 20%
 Preț: 1025.20 lei
- 18%
 Preț: 1042.80 lei
- 18%
 Preț: 780.39 lei
- 18%
 Preț: 1053.99 lei
- 18%
 Preț: 1160.53 lei
- 18%
 Preț: 1633.76 lei
- 20%
 Preț: 1205.57 lei
- 18%
 Preț: 1156.95 lei
- 18%
 Preț: 986.78 lei
- 20%
 Preț: 1526.11 lei
- 18%
 Preț: 1443.40 lei
- 20%
 Preț: 1222.72 lei
- 18%
 Preț: 1736.99 lei
- 20%
 Preț: 1026.22 lei
- 20%
 Preț: 381.73 lei
- 20%
 Preț: 1327.60 lei
- 18%
 Preț: 1640.66 lei
- 18%
 Preț: 1160.99 lei
- 20%
 Preț: 1212.51 lei
- 18%
 Preț: 1457.64 lei
- 18%
 Preț: 996.30 lei
- 18%
 Preț: 782.26 lei
- 20%
 Preț: 1210.01 lei
- 20%
 Preț: 1086.50 lei
- 18%
 Preț: 1291.32 lei
- 18%
 Preț: 1620.89 lei
- 18%
 Preț: 1039.94 lei
- 18%
 Preț: 1270.38 lei
- 18%
 Preț: 1277.06 lei
- 18%
 Preț: 1322.70 lei
- 20%
 Preț: 1966.68 lei
- 20%
 Preț: 1080.51 lei
- 18%
 Preț: 926.98 lei
- 20%
 Preț: 1727.09 lei
- 18%
 Preț: 786.67 lei
- 18%
 Preț: 1273.96 lei
- 18%
 Preț: 1154.37 lei
- 18%
 Preț: 1155.03 lei
Preț: 1039.23 lei
Preț vechi: 1267.35 lei
-18%
Puncte Express: 1559
Carte tipărită la comandă
Livrare economică 14-28 decembrie
Livrare prin curier în România Termenul estimat este afișat lângă disponibilitate.
Transport gratuit pentru acest produs Plată online sau ramburs, în funcție de opțiunile comenzii.
Retur gratuit în 14 zile Comandă securizată și suport în română.
Specificații
ISBN-13: 9783030868925
ISBN-10: 3030868923
Pagini: 256
Ilustrații: XX, 235 p. 112 illus., 110 illus. in color.
Dimensiuni: 160 x 241 x 20 mm
Greutate: 0.5 kg
Ediția:1st ed. 2022
Editura: Springer
Colecția Studies in Systems, Decision and Control
Seria Studies in Systems, Decision and Control
Locul publicării:Cham, Switzerland
ISBN-10: 3030868923
Pagini: 256
Ilustrații: XX, 235 p. 112 illus., 110 illus. in color.
Dimensiuni: 160 x 241 x 20 mm
Greutate: 0.5 kg
Ediția:1st ed. 2022
Editura: Springer
Colecția Studies in Systems, Decision and Control
Seria Studies in Systems, Decision and Control
Locul publicării:Cham, Switzerland
Cuprins
Introduction.- Preliminaries on System Theory and Optimization Algorithms.- Interaction Topology of Multiagent Systems and Consensus Protocols.- Emergent Behavior Detection in Multiagent Systems.- Distributed Task Coordination of Multiagent Systems.- Multiagent Task Coordination Using Approximate Dynamic Programming.- Distributed Gradient Estimation for Multiagent Task Optimization.- Case Studies and Experiments.
Notă biografică
Jing Wang received the B.S. degree in Industry Automation and the Ph.D. degree in Control Theory and Control Engineering from the Northeastern University, in 1994 and 1998, respectively. She was a professor with the College of Information Science and Technology, Beijing University of Chemical Technology, Beijing, China, from 1999 to 2020, and a visiting professor at University of Delaware, USA, in 2014. Now she is a professor with School of Electrical and Control Engineering, North China University of Technology, Beijing, China. Her research interest is oriented to different aspects, including modeling, optimization, advance control, process monitoring, and fault diagnosis for complex industrial process; industrial artificial intelligence based on analysis and learning from big data.
Jinglin Zhou received the B.Eng., M.Sc., and Ph.D. degrees from Daqing Petroleum Institute, Hunan University, Changsha, China, and the Institute of Automation, Chinese Academyof Sciences, Beijing, China, in 1999, 2002, and 2005, respectively. He was Academic Visitor with the Department of Automatic Control and Systems Engineering, University of Sheffield, Sheffield, UK. He is currently Professor with the College of Information Science and Technology, Beijing University of Chemical Technology, Beijing. His current research interests include stochastic distribution control, fault detection and diagnosis, variable structure control, and their applications.
Xiaolu Chen received the Ph.D. degree in Control Science and Engineering from Beijing University of Chemical Technology in 2021. She was a joint PhD student at the University of Duisburg Essen, Duisburg, Germany, from 2019 to 2020. Now she is a postdoctoral fellow at Peking University, Beijing, China. Her major is control science and engineering. Her research interests include modelling and fault diagnosis of complex industrial processes, data causality analysis, and intelligent learning algorithms.
Textul de pe ultima copertă
This book addresses problems in the modeling, detection, and control of emergent behaviors and task coordination in multiagent systems. It presents a unified solution to such problems in terms of distributed estimation, distributed control, and optimization of interaction topologies and dynamics.
Four aspects of the technical solutions in the book are presented: First, the impact of interaction dynamics on the convergence conditions related to interaction topologies is discussed, utilizing a discontinuous cooperative control algorithm of updated design. Second, distributed least-squares and Kalman filtering algorithms for agents with limited interactions are elaborated upon. Third, a general framework of distributed nonlinear control is established, and distributed adaptive control for nonlinear systems with more general uncertainties is presented. Based on the proposed framework, a distributed nonlinear controller is designed to deal with task coordination of robotic systems with nonholonomic constraints. Finally, the problem of optimal multiagent task coordination is addressed and solutions based on approximate dynamic programming and approximate distributed gradient estimation are presented.
Emergent Behavior Detection and Task Coordination for Multiagent Systems is of interest to practicing engineers in areas such as robotics and cyber-physical systems, researchers in the field of systems, controls, and robotics, and senior undergraduate and graduate students.
Four aspects of the technical solutions in the book are presented: First, the impact of interaction dynamics on the convergence conditions related to interaction topologies is discussed, utilizing a discontinuous cooperative control algorithm of updated design. Second, distributed least-squares and Kalman filtering algorithms for agents with limited interactions are elaborated upon. Third, a general framework of distributed nonlinear control is established, and distributed adaptive control for nonlinear systems with more general uncertainties is presented. Based on the proposed framework, a distributed nonlinear controller is designed to deal with task coordination of robotic systems with nonholonomic constraints. Finally, the problem of optimal multiagent task coordination is addressed and solutions based on approximate dynamic programming and approximate distributed gradient estimation are presented.
Emergent Behavior Detection and Task Coordination for Multiagent Systems is of interest to practicing engineers in areas such as robotics and cyber-physical systems, researchers in the field of systems, controls, and robotics, and senior undergraduate and graduate students.
Caracteristici
Expands reader knowledge with novel results on interaction topology and dynamics of multiagent systems Reinforces theoretical principles with practically applicable solutions to the multiagent task coordination problem Establishes useful guidelines for practicing engineers with test results from various robot platforms