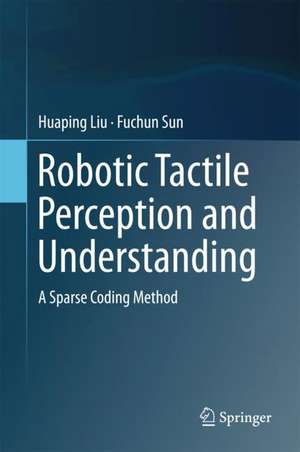
Robotic Tactile Perception and Understanding
Autor Fuchun Sun, Huaping Liuen Limba Engleză Hardback – 27 mar 2018
Preț: 848.28 lei
Preț vechi: 1060.36 lei
-20%
Puncte Express: 1272
Carte tipărită la comandă
Livrare economică 05-19 decembrie
Livrare prin curier în România Termenul estimat este afișat lângă disponibilitate.
Transport gratuit pentru acest produs Plată online sau ramburs, în funcție de opțiunile comenzii.
Retur gratuit în 14 zile Comandă securizată și suport în română.
Specificații
ISBN-13: 9789811061707
ISBN-10: 981106170X
Pagini: 228
Ilustrații: XX, 207 p. 131 illus., 37 illus. in color.
Dimensiuni: 160 x 241 x 18 mm
Greutate: 0.46 kg
Ediția:1st edition 2018
Editura: Springer Nature Singapore
Locul publicării:Singapore, Singapore
ISBN-10: 981106170X
Pagini: 228
Ilustrații: XX, 207 p. 131 illus., 37 illus. in color.
Dimensiuni: 160 x 241 x 18 mm
Greutate: 0.46 kg
Ediția:1st edition 2018
Editura: Springer Nature Singapore
Locul publicării:Singapore, Singapore
V-ar putea interesa
-
 -27%Preț: 822.57 lei1126.81 lei
-
 -20%Preț: 687.21 lei859.02 lei
-
 Stable Mutations for Evolutionary AlgorithmsAndrzej Obuchowicz-20%Preț: 668.51 lei835.64 lei
-
 Multi-Agent Systems and Agreement TechnologiesFrancesco Belardinelli-20%Preț: 350.57 lei438.22 lei
-
 -20%Preț: 1023.18 lei1278.96 lei
-
 Empirical Approach to Machine LearningPlamen P. Angelov-20%Preț: 1215.11 lei1518.88 lei
-
 Automated Invention for Smart IndustriesDenis Cavallucci-20%Preț: 374.17 lei467.71 lei
-
 Regulation Fixtures in Hydronic Heating InstallationsDamian Piotr Muniak-20%Preț: 679.56 lei849.46 lei
-
 Smart Techniques for a Smarter PlanetManoj Kumar Mishra-20%Preț: 1030.26 lei1287.82 lei
-
 Image Processing and Communications Challenges 10Micha¿ Chora¿-20%Preț: 633.39 lei791.74 lei
-
 Telematics and ComputingMiguel Felix Mata-Rivera-20%Preț: 335.02 lei418.78 lei
-
 Handbook of Genetic Programming ApplicationsAmir H. Gandomi-20%Preț: 1046.40 lei1308.00 lei
-
 New Frontiers in Information and Production Systems Modelling and AnalysisPrzemys¿aw Ró¿ewski-20%Preț: 674.03 lei842.53 lei
-
 Agent Environments for Multi-Agent Systems IVDanny Weyns-20%Preț: 320.50 lei400.63 lei
-
 Artificial Intelligence Applications and InnovationsRichard Chbeir-20%Preț: 710.86 lei888.57 lei
-
 -20%Preț: 646.65 lei808.31 lei
-
 KI 2015: Advances in Artificial IntelligenceSteffen Hölldobler-20%Preț: 339.73 lei424.66 lei
-
 -20%Preț: 337.81 lei422.26 lei
-
 Novel Developments in Uncertainty Representation and ProcessingKrassimir T. Atanassov-20%Preț: 950.36 lei1187.94 lei
-
 Trends and Applications in Software EngineeringJezreel Mejía-20%Preț: 629.97 lei787.47 lei
-
 -20%Preț: 972.60 lei1215.75 lei
-
 -20%Preț: 1276.71 lei1595.89 lei
-
 Knowledge Engineering and ManagementFuchun Sun-20%Preț: 1260.50 lei1575.63 lei
-
 -20%Preț: 1264.53 lei1580.67 lei
-
 Scholarpedia of TouchTony Prescott-20%Preț: 1173.69 lei1467.12 lei
-
 Multiview Machine LearningShiliang Sun-20%Preț: 962.58 lei1203.23 lei
-
 Cognitive Systems and Signal ProcessingFuchun Sun-20%Preț: 341.25 lei426.56 lei
Cuprins
Introduction.- Representation of Tactile and Visual Modalities.- Tactile Object Recognition using Joint Sparse Coding.- Tactile Object Recognition using Supervised Dictionary Learning.- Tactile Adjective Understanding using Structured Output-Associated Dictionary Learning.- Tactile Material Identification using Semantics-Regularized Dictionary Learning.- Visual-Tactile Fusion Object Recognition using Joint Sparse Coding.- Visual-Tactile Fusion Material Identification using Dictionary Learning.- Visual-Tactile Cross-Modal Matching using Common Dictionary Learning.-Conclusions.
Notă biografică
Bin Fang is an Assistant Researcher at the Department of Computer Science and Technology, Tsinghua University. His main research interests include wearable devices and human-robot interaction. He is a leader guest editor for a number of journals, including Frontiers in Neurorobotics, and Frontiers in Robotics and AI, and has served as an associate editor for various journals and conferences, e.g. the International Journal of Advanced Robotic Systems, and the IEEE International Conference on Advanced Robotics and Mechatronics.
Fuchun Sun is a Full Professor at the Department of Computer Science and Technology, Tsinghua University. A recipient of the National Science Fund for Distinguished Young Scholars, his main research interests include intelligent control and robotics. He serves as an associate editor for a number of international journals, including IEEE Transactions on Systems, Man and Cybernetics: Systems, IEEE Transactions on Fuzzy Systems, and Mechatronics, Robotics and Autonomous Systems.
Huaping Liu is an Associate Professor at the Department of Computer Science and Technology, Tsinghua University. His main research interests include robotic perception and learning. He serves as an associate editor for various journals, including IEEE Transactions on Automation Science and Engineering, IEEE Transactions on Industrial Informatics, IEEE Robotics & Automation Letters, Neurocomputing, and Cognitive Computation.
¿Chunfang Liu is an Assistant Professor at the Department of Artificial Intelligence and Automation, Beijing University of Technology. Her research interests include intelligent robotics and vision.
Di Guo received her Ph.D. degree from the Department of Computer Science and Technology, Tsinghua University, Beijing, in 2017. Her research interests include robotic manipulation and sensor fusion.
Textul de pe ultima copertă
This book introduces the challenges of robotic tactile perception and task understanding, and describes an advanced approach based on machine learning and sparse coding techniques. Further, a set of structured sparse coding models is developed to address the issues of dynamic tactile sensing. The book then proves that the proposed framework is effective in solving the problems of multi-finger tactile object recognition, multi-label tactile adjective recognition and multi-category material analysis, which are all challenging practical problems in the fields of robotics and automation. The proposed sparse coding model can be used to tackle the challenging visual-tactile fusion recognition problem, and the book develops a series of efficient optimization algorithms to implement the model. It is suitable as a reference book for graduate students with a basic knowledge of machine learning as well as professional researchers interested in robotic tactile perception and understanding, and machine learning.
Caracteristici
Provides a systematic and comprehensive introduction to robotic tactile perception and understanding
Introduces machine-learning-based solutions for tactile perception and understanding
Showcase the applications of sparse coding methods
Introduces machine-learning-based solutions for tactile perception and understanding
Showcase the applications of sparse coding methods