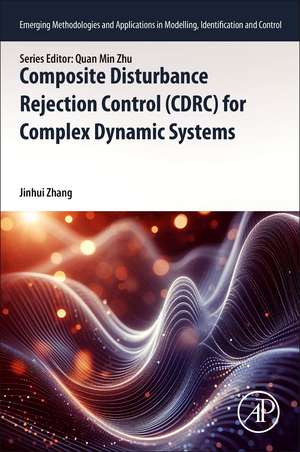
Composite Disturbance Rejection Control (CDRC) for Complex Dynamic Systems: Emerging Methodologies and Applications in Modelling, Identification and Control
Autor Jinhui Zhangen Limba Engleză Paperback – 9 iul 2025
- Offers a comprehensive exploration of control strategies across multiple chapters
- Deepens reader understanding of these methods and enhances their ability to select the most suitable approach for specific situations
- Introduces a range of Combined Disturbance Rejection Control (CDRC) methods created by merging different disturbance rejection control techniques.
- Provides readers with innovative approaches to designing control systems tailored to diverse scenarios
- Presents numerous examples and solutions for industrial control systems
Din seria Emerging Methodologies and Applications in Modelling, Identification and Control
- 40%
 Preț: 796.37 lei
- 29%
 Preț: 805.05 lei
- 32%
 Preț: 720.09 lei
- 30%
 Preț: 744.75 lei
- 24%
 Preț: 608.82 lei
- 38%
 Preț: 772.54 lei
- 28%
 Preț: 765.88 lei
- 23%
 Preț: 912.61 lei
- 28%
 Preț: 914.06 lei
- 39%
 Preț: 915.31 lei
- 29%
 Preț: 1115.86 lei
- 23%
 Preț: 769.84 lei
- 20%
 Preț: 956.54 lei
- 20%
 Preț: 954.40 lei
- 20%
 Preț: 954.94 lei
- 9%
 Preț: 660.33 lei
- 31%
 Preț: 790.29 lei
- 29%
 Preț: 758.32 lei
- 25%
 Preț: 702.54 lei
- 26%
 Preț: 692.54 lei
- 24%
 Preț: 756.91 lei
- 33%
 Preț: 1054.36 lei
- 9%
 Preț: 1058.60 lei
- 9%
 Preț: 747.67 lei
- 25%
 Preț: 824.03 lei
- 30%
 Preț: 770.63 lei
- 30%
 Preț: 650.66 lei
- 30%
 Preț: 1001.59 lei
- 25%
 Preț: 796.35 lei
- 25%
 Preț: 844.39 lei
- 31%
 Preț: 994.36 lei
- 30%
 Preț: 976.13 lei
- 47%
 Preț: 952.77 lei
- 38%
 Preț: 912.18 lei
Preț: 1059.08 lei
Preț vechi: 1409.17 lei
-25%
Carte tipărită la comandă
Livrare economică 15-29 decembrie
Specificații
ISBN-10: 0443300569
Pagini: 322
Dimensiuni: 152 x 229 mm
Greutate: 0.52 kg
Editura: ELSEVIER SCIENCE
Seria Emerging Methodologies and Applications in Modelling, Identification and Control
V-ar putea interesa
-
 Formal Methods for Multi-Agent Feedback Control SystemsDimos V. Dimarogonas-20%Preț: 610.14 lei762.68 lei
-
 -23%Preț: 175.25 lei227.99 lei
-
 Optimal Control and EstimationRobert F. Stengel-19%Preț: 215.01 lei264.50 lei
-
 Linear Multivariable Control SystemsShankar P Bhattacharyya-11%Preț: 671.72 lei754.73 lei
-
 Aircraft Control and SimulationBrian L Stevens-23%Preț: 956.58 lei1242.31 lei
-
 -15%Preț: 694.35 lei816.88 lei
-
 Linear Parameter-Varying ControlOlivier Sename-23%Preț: 718.87 lei933.60 lei
-
 Structural Control and Fault Detection of Wind Turbine SystemsHamid Reza Karimi-18%Preț: 816.34 lei995.54 lei
-
 -24%Preț: 1290.90 lei1698.56 lei
-
 Sliding-Mode Control and Variable-Structure SystemsTiago Roux Oliveira-18%Preț: 1457.64 lei1777.61 lei
-
 Robust and Adaptive ControlEugene LavretskyPreț: 542.07 lei
-
 Automotive Air ConditioningQuansheng Zhang-9%Preț: 712.95 lei783.46 lei
-
 Advanced Control Methods for Industrial ProcessesPablo A. López-Pérez-23%Preț: 701.54 lei911.09 lei
-
 Advanced Control Systems: Theory and ApplicationsYuriy P. Kondratenko-23%Preț: 686.57 lei891.64 lei
-
 -24%Preț: 896.69 lei1179.85 lei
-
 -18%Preț: 1449.74 lei1767.97 lei
-
 Singularly Perturbed Jump SystemsHao Shen-18%Preț: 853.86 lei1041.29 lei
-
 Advanced Attitude Control of SatelliteBing Xiao-18%Preț: 924.64 lei1127.60 lei
Cuprins
Part I CDRC Methods for Complex Dynamic Systems:
2. DOB and ISMC Based CDRC for Systems With Disturbances
3. ESO Based Cooperative CDRC for Multi-Agent Systems With Disturbances
4. DOB Based CDRC for Markovian Jumping Systems With Disturbances
5. Extended SMO Based CDRC for Markovian Jumping Systems With Disturbances
6. Fuzzy SMC for Nonlinear Systems With Disturbances
7. DOB and SMC Based Fuzzy Fixed-Time CDRC for Nonlinear Systems With Disturbances
Part II CDRC Applications
8. ESO-Based Composite Attitude Control for Quadrotor with Disturbances
9. DOB-Based Composite Attitude Control for Rigid Spacecraft With Disturbances
10. DOB-Based Composite Trajectory Tracking Control for Robot Manipulator With Disturbances
11. Variable Gain Composite Trajectory Tracking Control for Four-Mecanum-Wheel Mobile Vehicle
12. Variable Gain Composite Trajectory Tracking Control of Pneumatic Servo System
Notă biografică
Jinhui Zhang earned his Ph.D. in Control Science and Engineering from Beijing Institute of Technology, China, in 2011. Prior to that, he held research roles at the University of Hong Kong and City University of Hong Kong in 2010-2011. He also served as a Visiting Fellow at the University of Western Sydney, Australia, in 2013.
Later, he became an Associate Professor at Beijing University of Chemical Technology from 2011 to 2016 and a Professor at Tianjin University's School of Electrical and Automation Engineering from 2016 to 2016. Since joining Beijing Institute of Technology in October 2016, he has held the position of Professor. His research centres on networked control systems and composite disturbance rejection control.