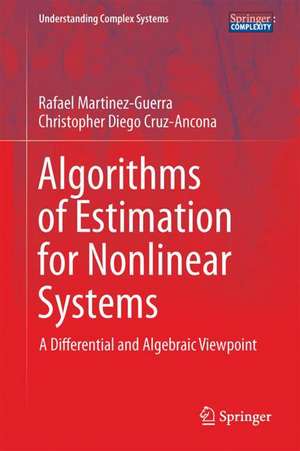
Algorithms of Estimation for Nonlinear Systems: Understanding Complex Systems
Autor Rafael Martínez-Guerra, Christopher Diego Cruz-Anconaen Limba Engleză Hardback – 18 apr 2017
Several algorithms are proposed and worked out for a set of model systems, in particular so-called input-affine or bilinear systems, which can serve to approximate a wide class of nonlinear control systems. These can either take the form of state space models or be represented by an input-output equation.
The approach taken here further highlights the role of modern mathematical and conceptual tools, including differential algebraic theory, observer design for nonlinear systems and generalized canonical forms.
Din seria Understanding Complex Systems
- 18%
 Preț: 1080.00 lei
-
 Preț: 439.80 lei
- 18%
 Preț: 988.65 lei
- 15%
 Preț: 661.12 lei
- 18%
 Preț: 1170.06 lei
- 18%
 Preț: 911.29 lei
- 15%
 Preț: 667.19 lei
- 15%
 Preț: 673.77 lei
- 15%
 Preț: 675.52 lei
- 18%
 Preț: 955.93 lei
- 18%
 Preț: 990.14 lei
- 15%
 Preț: 666.14 lei
- 15%
 Preț: 663.50 lei
-
 Preț: 442.26 lei
- 15%
 Preț: 661.83 lei
- 15%
 Preț: 677.28 lei
- 15%
 Preț: 666.40 lei
- 20%
 Preț: 674.28 lei
- 20%
 Preț: 677.98 lei
- 18%
 Preț: 982.53 lei
- 18%
 Preț: 1150.57 lei
- 18%
 Preț: 1280.17 lei
- 15%
 Preț: 668.60 lei
- 18%
 Preț: 983.43 lei
- 15%
 Preț: 669.20 lei
- 18%
 Preț: 1440.00 lei
- 18%
 Preț: 990.35 lei
-
 Preț: 414.85 lei
- 18%
 Preț: 980.03 lei
- 18%
 Preț: 1297.31 lei
- 15%
 Preț: 666.97 lei
- 5%
 Preț: 1465.64 lei
- 18%
 Preț: 984.66 lei
- 18%
 Preț: 982.96 lei
-
 Preț: 402.76 lei
- 20%
 Preț: 680.46 lei
- 18%
 Preț: 1047.87 lei
Preț: 723.99 lei
Preț vechi: 851.75 lei
-15%
Puncte Express: 1086
Carte tipărită la comandă
Livrare economică 27 noiembrie-11 decembrie
Livrare prin curier în România Termenul estimat este afișat lângă disponibilitate.
Transport gratuit pentru acest produs Plată online sau ramburs, în funcție de opțiunile comenzii.
Retur gratuit în 14 zile Comandă securizată și suport în română.
Specificații
ISBN-13: 9783319530390
ISBN-10: 3319530399
Pagini: 220
Ilustrații: XX, 197 p. 58 illus., 10 illus. in color.
Dimensiuni: 160 x 241 x 18 mm
Greutate: 0.45 kg
Ediția:1st edition 2017
Editura: Springer
Colecția Understanding Complex Systems
Seria Understanding Complex Systems
Locul publicării:Cham, Switzerland
ISBN-10: 3319530399
Pagini: 220
Ilustrații: XX, 197 p. 58 illus., 10 illus. in color.
Dimensiuni: 160 x 241 x 18 mm
Greutate: 0.45 kg
Ediția:1st edition 2017
Editura: Springer
Colecția Understanding Complex Systems
Seria Understanding Complex Systems
Locul publicării:Cham, Switzerland
V-ar putea interesa
-
 Complexity: A Very Short IntroductionJohn H. Holland-20%Preț: 56.65 lei70.82 lei
-
 Nonlinear SystemsShankar Sastry-15%Preț: 682.48 lei802.92 lei
-
 Preț: 325.10 lei
-
 Pattern Formation and Dynamics in Nonequilibrium SystemsMichael Cross-14%Preț: 828.27 lei963.10 lei
-
 Preț: 454.49 lei
-
 -9%Preț: 838.76 lei921.71 lei
-
 Mathematical Methods in Biology and NeurobiologyJürgen Jost-15%Preț: 472.24 lei555.58 lei
-
 Isospectral TransformationsLeonid BunimovichPreț: 402.24 lei
-
 Henri Poincaré, 1912-2012Bertrand Duplantier-18%Preț: 812.88 lei991.31 lei
-
 Dynamics of Quasi-Stable Dissipative SystemsIgor ChueshovPreț: 397.95 lei
-
 Preț: 346.73 lei
Cuprins
Preface.- Analysis of input-affine nonlinear processes.- Basic Definitions of Differential Algebras.- Algebraic Observability Condition for Nonlinear systems and External behaviour.- Generalized Observability Canonical Forms.- Observer Synthesis.- Tracking and Stabilization Problems.- Parametric and State Estimation.- Observer synthesis for a more general class of Nonlinear Systems.- A Separation Principle for Nonlinear Systems.- Some uncommon observers with interesting applications.- Appendix A Singularity Treatment.- Appendix B Some properties for Nonlinear Systems.
Recenzii
“Many examples are provided throughout the book to illustrate the methods described in each section. … the book provides an interesting overview of the potentialities of the differential algebraic approach and the relationships with analogous results from the differential geometric approach.” (Filippo Cacace, Mathematical Reviews, November, 2017)
Textul de pe ultima copertă
This book acquaints readers with recent developments in dynamical systems theory and its applications, with a strong focus on the control and estimation of nonlinear systems.
Several algorithms are proposed and worked out for a set of model systems, in particular so-called input-affine or bilinear systems, which can serve to approximate a wide class of nonlinear control systems. These can either take the form of state space models or be represented by an input-output equation.
The approach taken here further highlights the role of modern mathematical and conceptual tools, including differential algebraic theory, observer design for nonlinear systems and generalized canonical forms.
Caracteristici
Introduces novel approaches to nonlinear control systems Self-contained presentation suitable also for newcomers to the field Contains many worked examples
Notă biografică
Rafael Martínez-Guerra earned his Ph.D. degree from Metropolitan Autonomous University (UAM) in 1996. Currently, he is a researcher at the Automatic Control Department of the Center for Research and Advanced Studies (CINVESTAV - IPN) and member of the National System of Researchers (SNI) since 1992. He is author and co-author of more than 80 papers in international journals and more than 130 contributions in international conference and proceedings. He is co-author of 7 books. His research interests are in the areas of nonlinear systems, differential geometric and differential algebraic methods, fractional nonlinear observers, fractional fault detection and diagnosis, secure communications, fractional synchronization and chaos.
Fidel Meléndez-Vázquez obtained the M.Eng. degree at the National Polytechnic Institute (IPN) and the Ph.D. degree in Science at the Center for Research and Advanced Studies (CINVESTAV - IPN), in Mexico City, where his research focused on fault diagnosis and rejection in integer and fractional-order systems. Currently, he is a Postdoctoral Assistant Researcher at the Universidad Iberoamericana in Mexico City, where he works on the theory and applications of fractional calculus. He has recently obtained the Appointment as Candidate in the National System of Researchers (SNI), awarded by the National Council of Science and Technology (CONACYT) from Mexico.
Iván Trejo-Zúñiga is Fulltime Professor in mechatronics at the Technological University of San Juan del Rio, Querétaro, Mexico. He obtained his Ph.D. in Automatic Control from the Center for Research and Advanced Studies (CINVESTAV - IPN). He is a member of the National System of Researchers (SNI) and conducts research on topics such as fault diagnosis, fault-tolerant control for integer and fractional-order systems, robust control, fractional differentiators and observers fordynamical systems.